Backend
A Controlled Study of Models, Skills, Feedback, and Curriculum in Agentic Robotics
arXiv cs.RO0 views
arXiv:2611.09030v1 Announce Type: new Abstract: Agentic robotics asks coding agents to implement and iteratively improve robot policies from simulated and real-world physical interactions. We study the self-learning loop of agentic robotics through a controlled simulation study spanning nine manipulation tasks, 631 different experiment configurations, and 28K coding agent rollouts, systematically varying model capability, skill priors, feedback structure, and curriculum. The experiment data suggests that the bottleneck is often not the access to sufficient information, but interpreting it into the right policy update. Across these factors, a successful self-learning loop depends on how effectively agents attribute failures, reason task-relevant spatial and geometric structure, and selectively restructure code to improve policies.
Source:https://arxiv.org/abs/2611.09030PreviousFASTFUNNELS: Agile Multi Robot Navigation in Narrow Spaces via Adaptive Dynamic FunnelsNextToolDex: An Ego-Exo Human Demonstration Dataset for Creative Physical Tool Use
Related posts

Breaking a Rust actor cluster on purpose, and what it taught us
0Hacker News New

Cargo's cache can't be reused with or without --target <target>
0Rust Users Forum
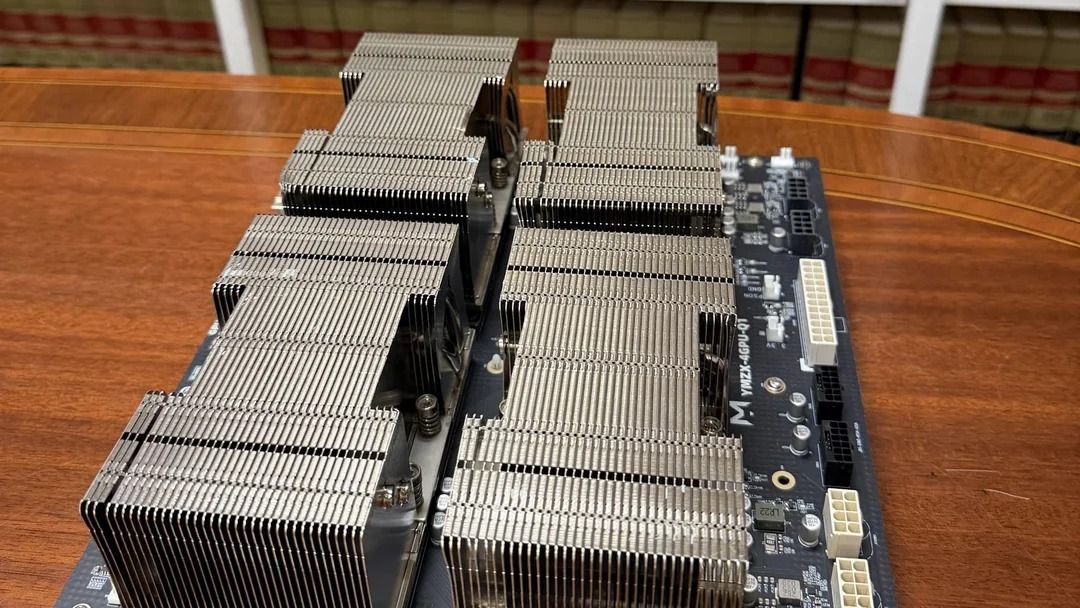
Lawyer builds private AI server with eight used Nvidia V100 GPUs
0Tom's Hardware
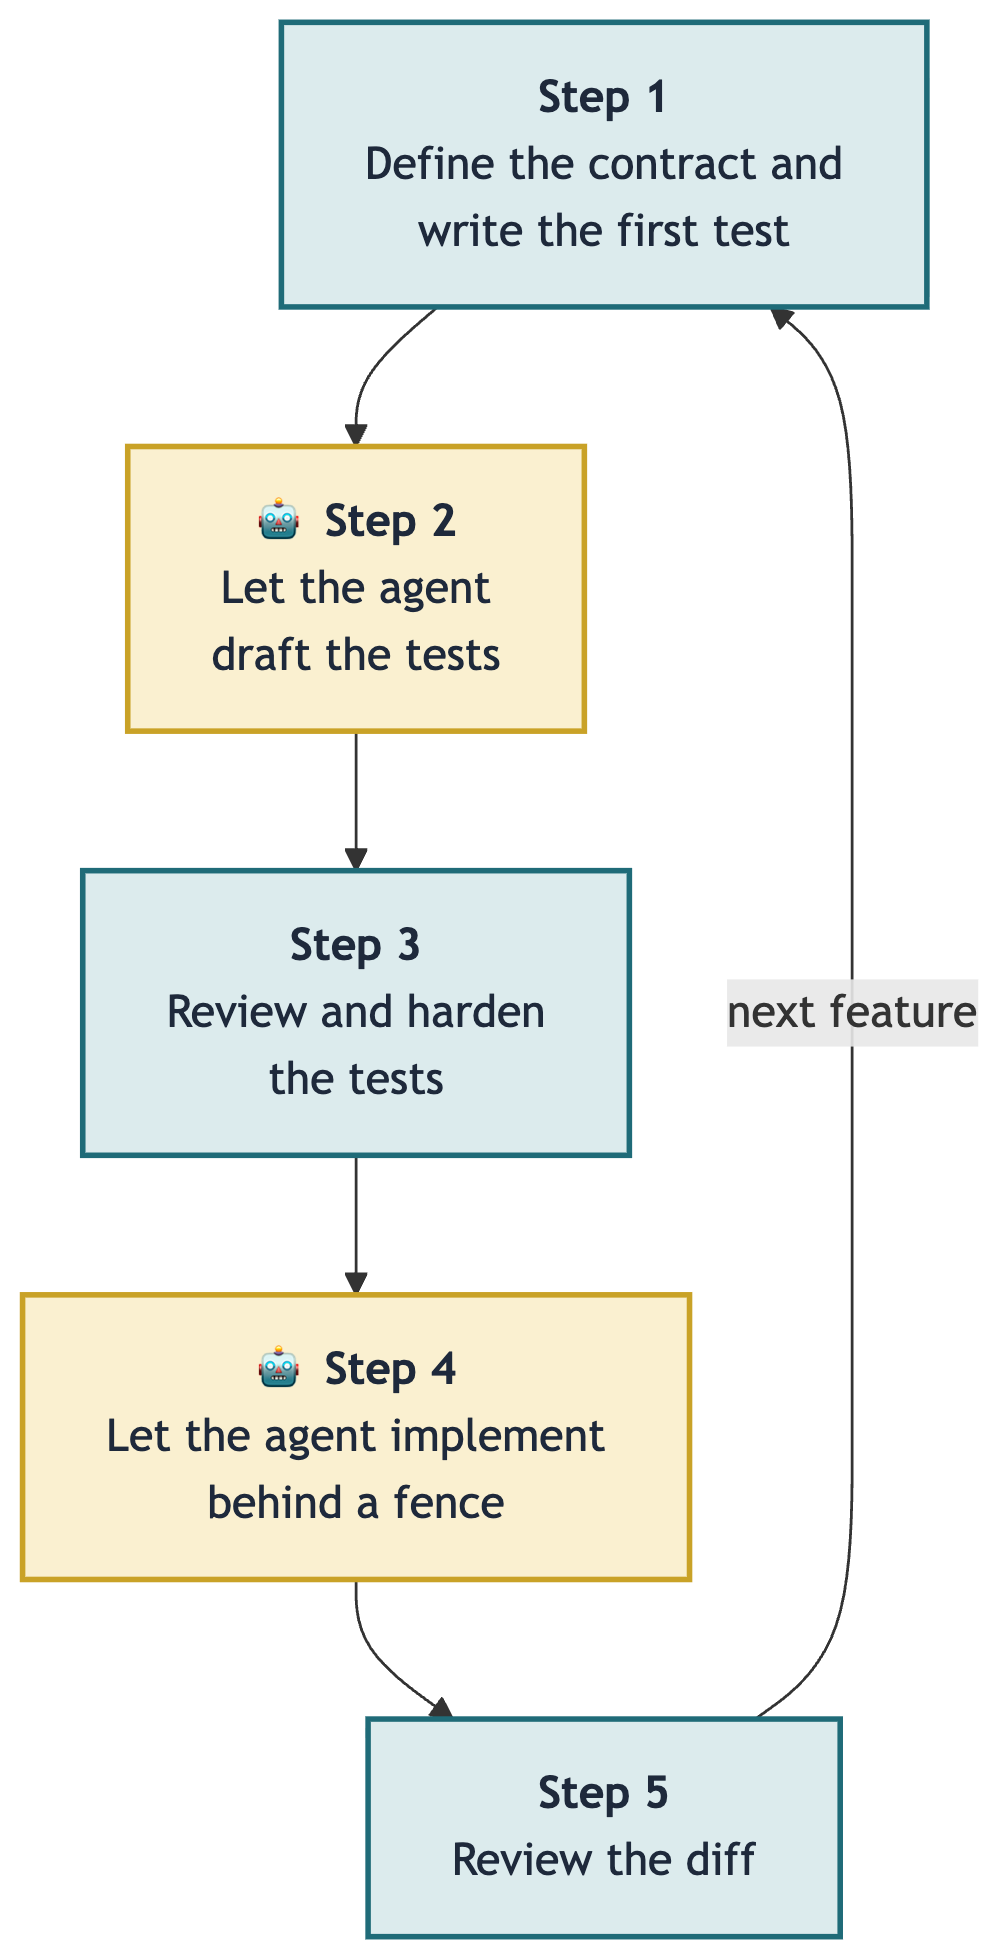
TDD With AI Agents: Design the Tests First, Let the Agent Implement
0Real Python

From One Sentence to a Working App: What Vibe Coding Gets Right — and Where It Still Needs You
0dev.to

A button people press 57 times per visit: building a no-backend tap counter that doesn't lose counts
0dev.to