AI & ML
Capability-Conditioned Graph Control Barrier Functions for Zero-Shot Safe Navigation of Heterogeneous Mobile Robot Teams
arXiv cs.RO0 views
arXiv:2610.41214v1 Announce Type: new Abstract: Multi-robot systems are increasingly deployed as heterogeneous fleets with diverse kinematic and actuation capabilities. While graph control barrier function (GCBF) methods provide a scalable framework for decentralized safe control, existing approaches typically assume homogeneous robot dynamics. Methods that directly encode robot classes can distinguish known types, but do not represent state-dependent motion capabilities or naturally transfer to unseen robot models. To address this challenge, we propose the Capability-Conditioned Heterogeneous Graph Control Barrier Function (CC-HGCBF), defined in a shared second-order reference-point operational space. This formulation provides a common geometric representation of safety across heterogeneous robots while retaining their model-specific dynamics and admissible control constraints. To enable zero-shot transfer, we introduce the Radial Capability Field (RCF), a compact, fixed-dimensional representation of each robot's state-dependent finite-horizon reachable velocity set. Conditioning the shared graph barrier and decentralized policy on the RCF enables them to adapt to changes in robot state, kinematic constraints, and control limits without relying on predefined robot identities. We jointly train the barrier and policy using proactive safety labeling and neural CBF-QP supervision, and evaluate them on mixed teams containing both seen and unseen robot models. Experiments demonstrate scalable safe coordination and zero-shot transfer to robot models and capability variations withheld during training. Physical-robot experiments further demonstrate zero-shot deployment to unseen kinematic models without retraining.
Source:https://arxiv.org/abs/2610.41214PreviousA Capability-Aware Backup-Recoverability Filter for Heterogeneous Multi-Robot NavigationNextTinyAstral: Transferring Self-Evolving Harnesses to Tiny Generalist Manipulation Agents
Related posts

Quantization, Explained: From FP32 to INT4, and What Each Precision Costs You
0dev.to AI

Black Friday hosting: how to tell a real deal from a fake one
0dev.to WebDev

The Nasdaq 100 drops 6%, losing a record $2.3T in value, and the Philadelphia chip index plunges 12%, on concerns over the AI trade after Democrats won Congress (Natalia Kniazhevich/Bloomberg)
0Techmeme
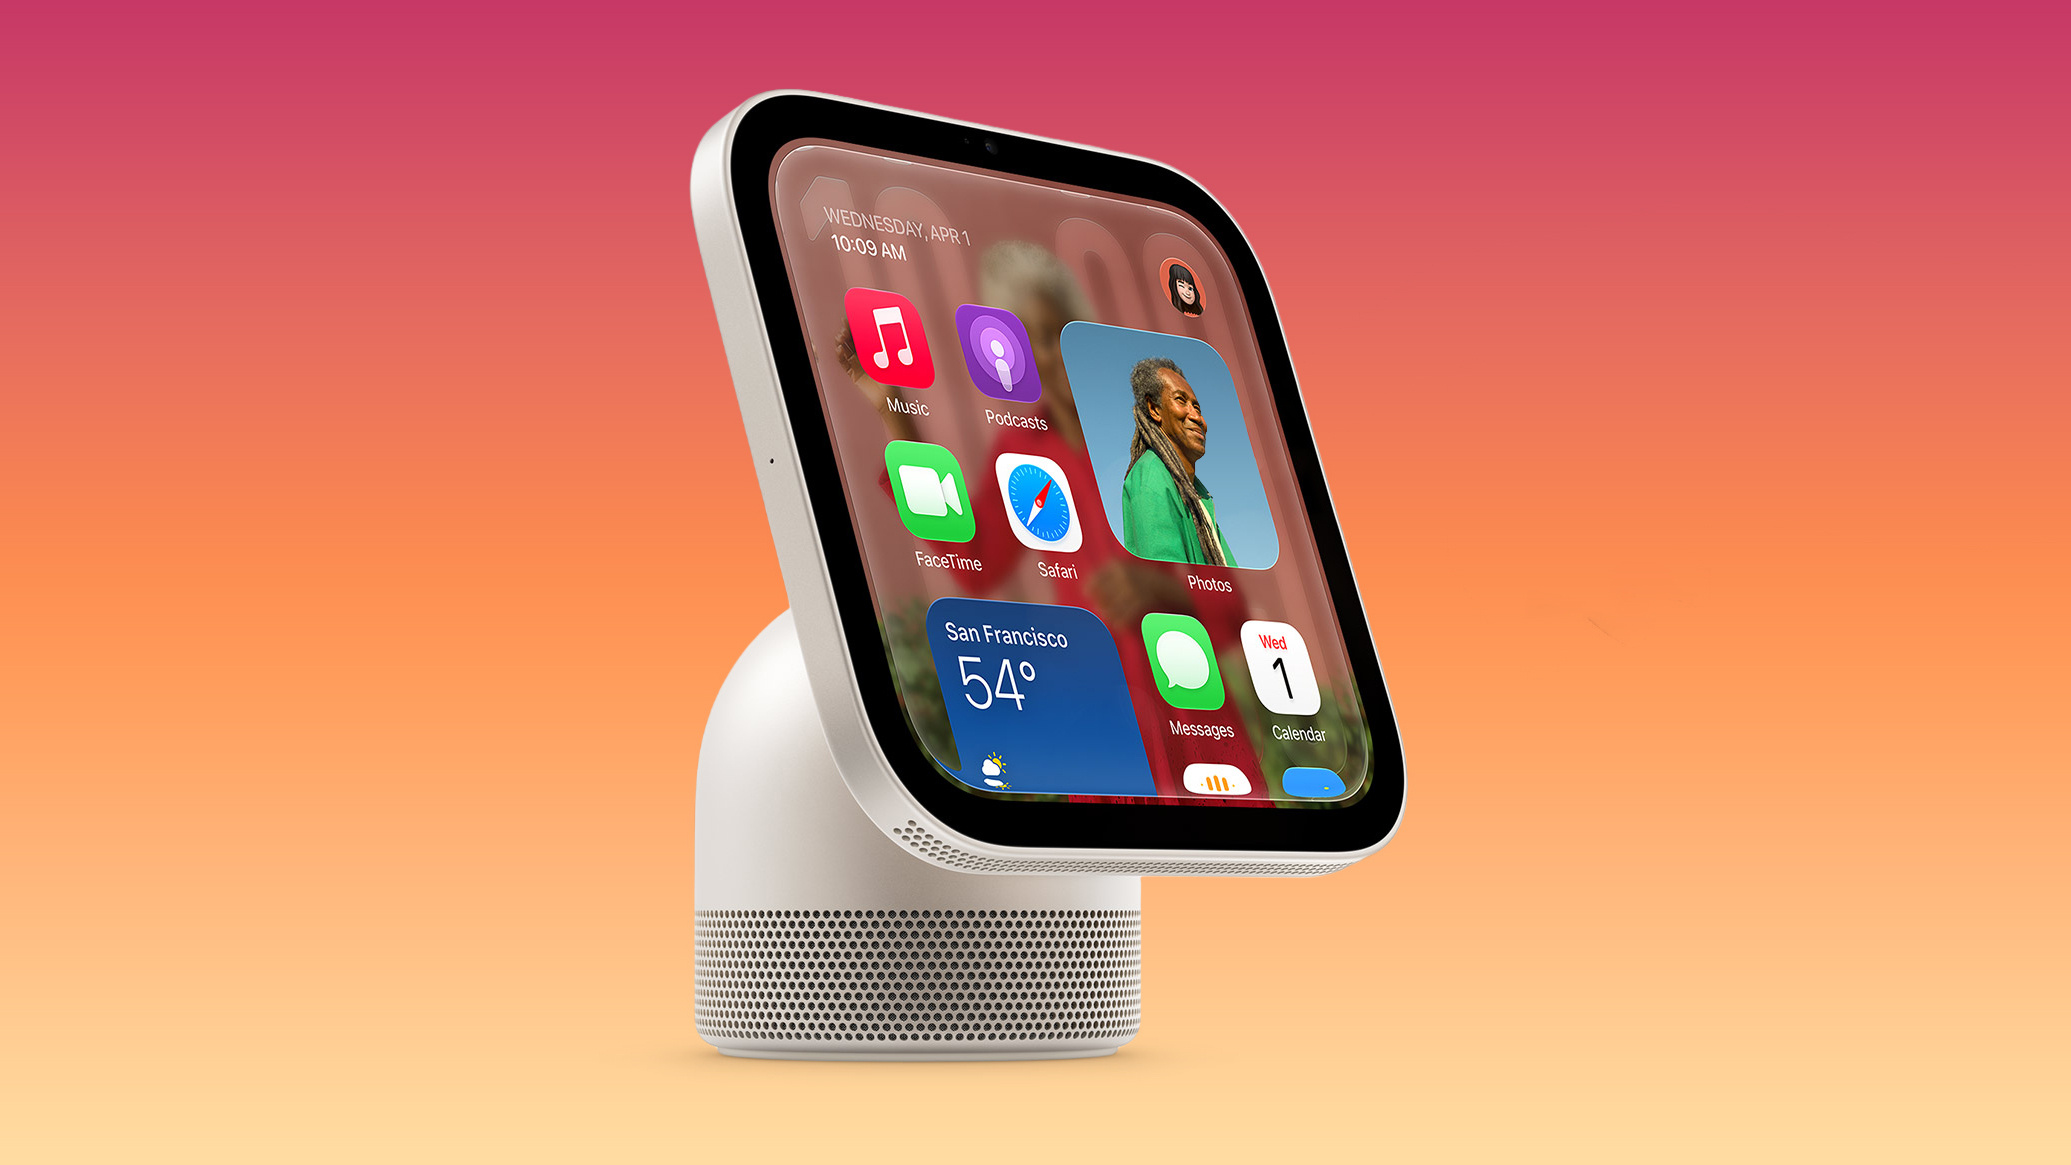
Apple's New HomeView Smart Home Hub: Here's How Much RAM It Has
0MacRumors

Rewind on an Older Apple Watch: Memova's Upcoming Feature
0Hacker News New

Plain Vanilla Web
0Hacker News New