AI & ML
Learning-based Autonomous Oversteer Control and Collision Avoidance
arXiv cs.RO0 views
arXiv:2505.15275v2 Announce Type: replace Abstract: Oversteer, wherein a vehicle's rear tires lose traction and induce unintentional excessive yaw, poses critical safety challenges. Failing to control oversteer often leads to severe traffic accidents. Although recent autonomous driving efforts have attempted to handle oversteer through stabilizing maneuvers, the majority rely on expert-defined trajectories or assume obstacle-free environments, limiting real-world applicability. This paper introduces a novel end-to-end (E2E) autonomous driving approach that tackles oversteer control and collision avoidance simultaneously. Existing E2E techniques, including Imitation Learning (IL), Reinforcement Learning (RL), and Hybrid Learning (HL), generally require near-optimal demonstrations or extensive experience. Yet even skilled human drivers struggle to provide perfect demonstrations under oversteer, and high transition variance hinders the accumulation of sufficient data. Hence, we present Q-Compared Soft Actor-Critic (QC-SAC), a new HL algorithm that effectively learns from immature demonstration data and adapts rapidly to new conditions. To evaluate QC-SAC, we introduce a benchmark inspired by real-world driver training: a vehicle encounters sudden oversteer on a slippery surface and must avoid randomly placed obstacles ahead. Experimental results show that QC-SAC attains near-optimal driving policies, significantly surpassing state-of-the-art IL, RL, and HL baselines. Hardware-in-the-loop simulation (HILS) validation with physical steering hardware further demonstrates that QC-SAC can operate beyond a software-only simulation, providing an intermediate validation step toward real-vehicle implementation. To the best of our knowledge, this is the first work that achieves safe autonomous control of vehicles in oversteer while simultaneously avoiding obstacles.
Source:https://arxiv.org/abs/2505.15275PreviousTraining-free Task-oriented Grasp GenerationNextLearned Controllers for Agile Quadrotors in Pursuit-Evasion Games
Related posts

Why I Built a Privacy-First ATS Resume Checker That Runs in the Browser
0dev.to

Local AI on a PC: what actually works (Whisper, translation, LLMs)
0dev.to

LLM assisted reverse engineering
0Hacker News

Palo Alto Networks to Acquire Applied Compute for $4.5B
0Hacker News
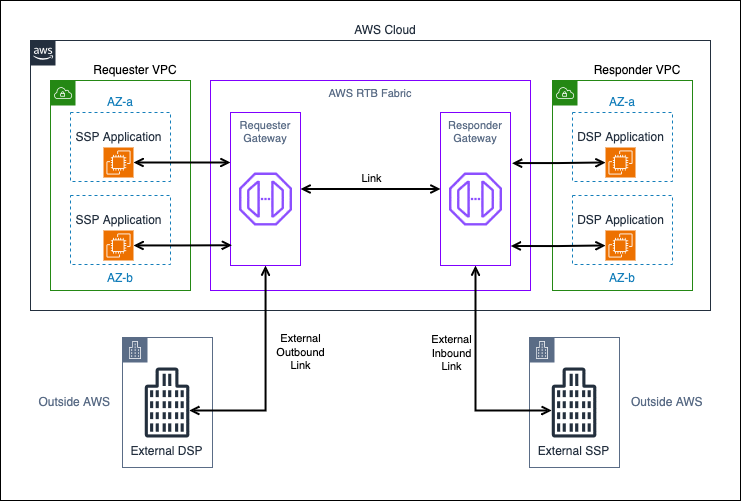
Building highly available real-time bidding workloads with AWS RTB Fabric
0AWS for Industries

Thống kê đối đầu Rayo Vallecano vs Valencia: Xu thế bế tắc và quy luật chia điểm áp đảo
0dev.to Data