AI & ML
Orbis 2: A Hierarchical World Model for Driving
arXiv cs.RO0 views
arXiv:2607.15898v2 Announce Type: replace-cross Abstract: Current world models operate at a single level of abstraction, with most prioritizing perceptual fidelity while lacking the spatial reasoning and semantic understanding required for real-world downstream tasks. We present a hierarchical driving world model that factorizes future prediction across two levels operating at distinct temporal and abstraction scales: a high-level predictor that forecasts coarse scene structure over extended temporal horizons, and a low-level generator that produces detailed predictions conditioned on the high-level output. This decomposition yields high perceptual fidelity while also capturing strong spatial and semantic representations. We further show that pretraining with a diffusion forcing objective yields substantially richer internal representations than the standard teacher forcing objective, while teacher forcing -- predicting only the next frame from clean context -- produces more stable autoregressive rollouts. We therefore introduce a generic two-stage training paradigm that pretrains the model with diffusion forcing and fine-tunes with teacher forcing, combining the representational benefits of the former with the rollout stability of the latter. Our approach achieves state-of-the-art results across the standard suite of driving world model evaluations on established benchmarks, including long-horizon generation fidelity, steering responsiveness evaluated on counterfactual scenarios, and internal representation quality. Project page with code, demo, checkpoints and qualitative results: https://lmb-freiburg.github.io/orbis2.github.io/
Source:https://arxiv.org/abs/2607.15898PreviousGrounding Driving VLA via Inverse KinematicsNextObserver-Assisted Relative-Velocity Compensation with LPV-$H_\infty$ Robust Correction for 3D Trajectory Tracking of Underactuated Non-Minimum-Phase AUVs under Ocean Currents
Related posts

Mobile Manipulation Software and Operations — Ch.09: MLOps [EN]
0dev.to Programming

Mobile Manipulation Software and Operations — Ch.02: MoveIt2 [EN]
0dev.to Programming

Five of my most-read catalog pages 404 because of a hyphen I never chose
0dev.to Database
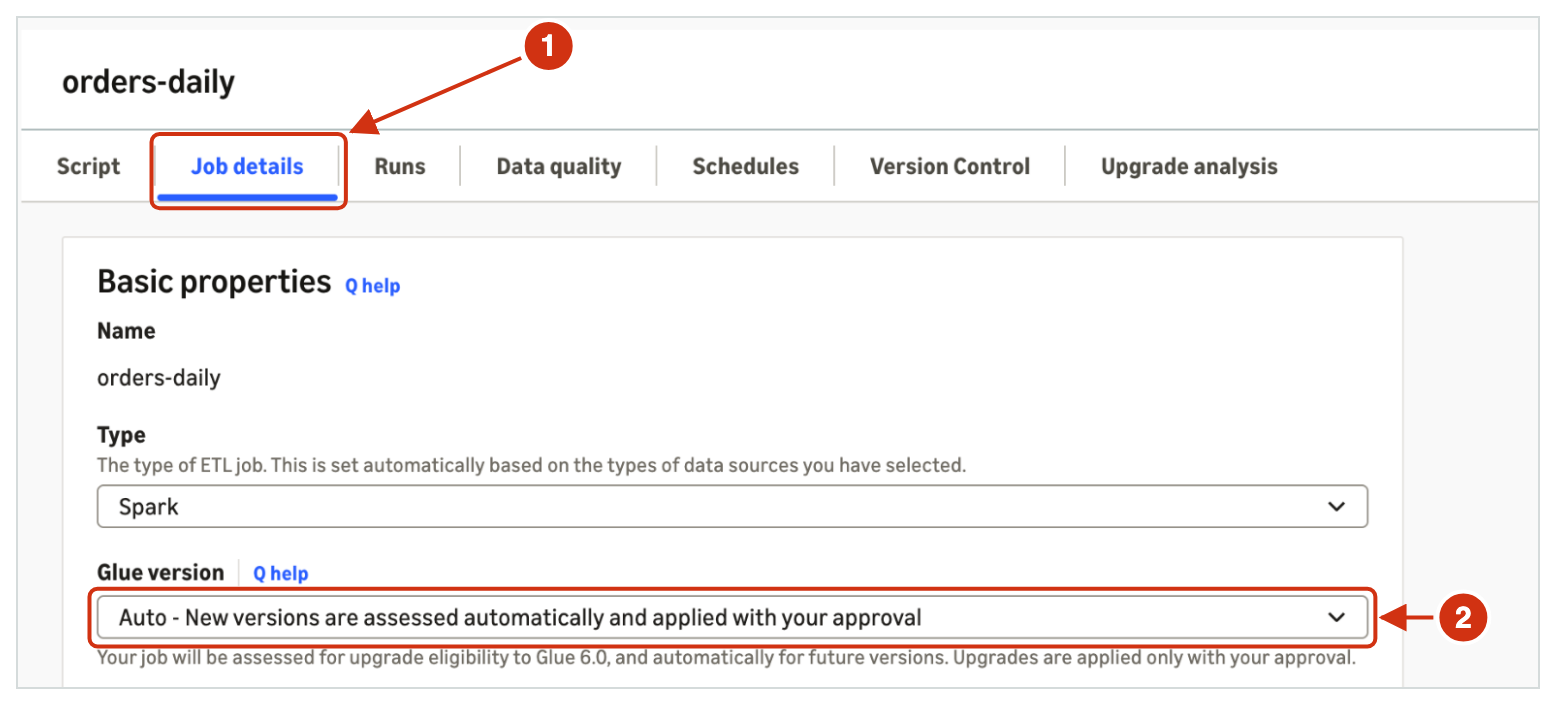
Introducing automatic version upgrades for AWS Glue jobs
0AWS Big Data Blog
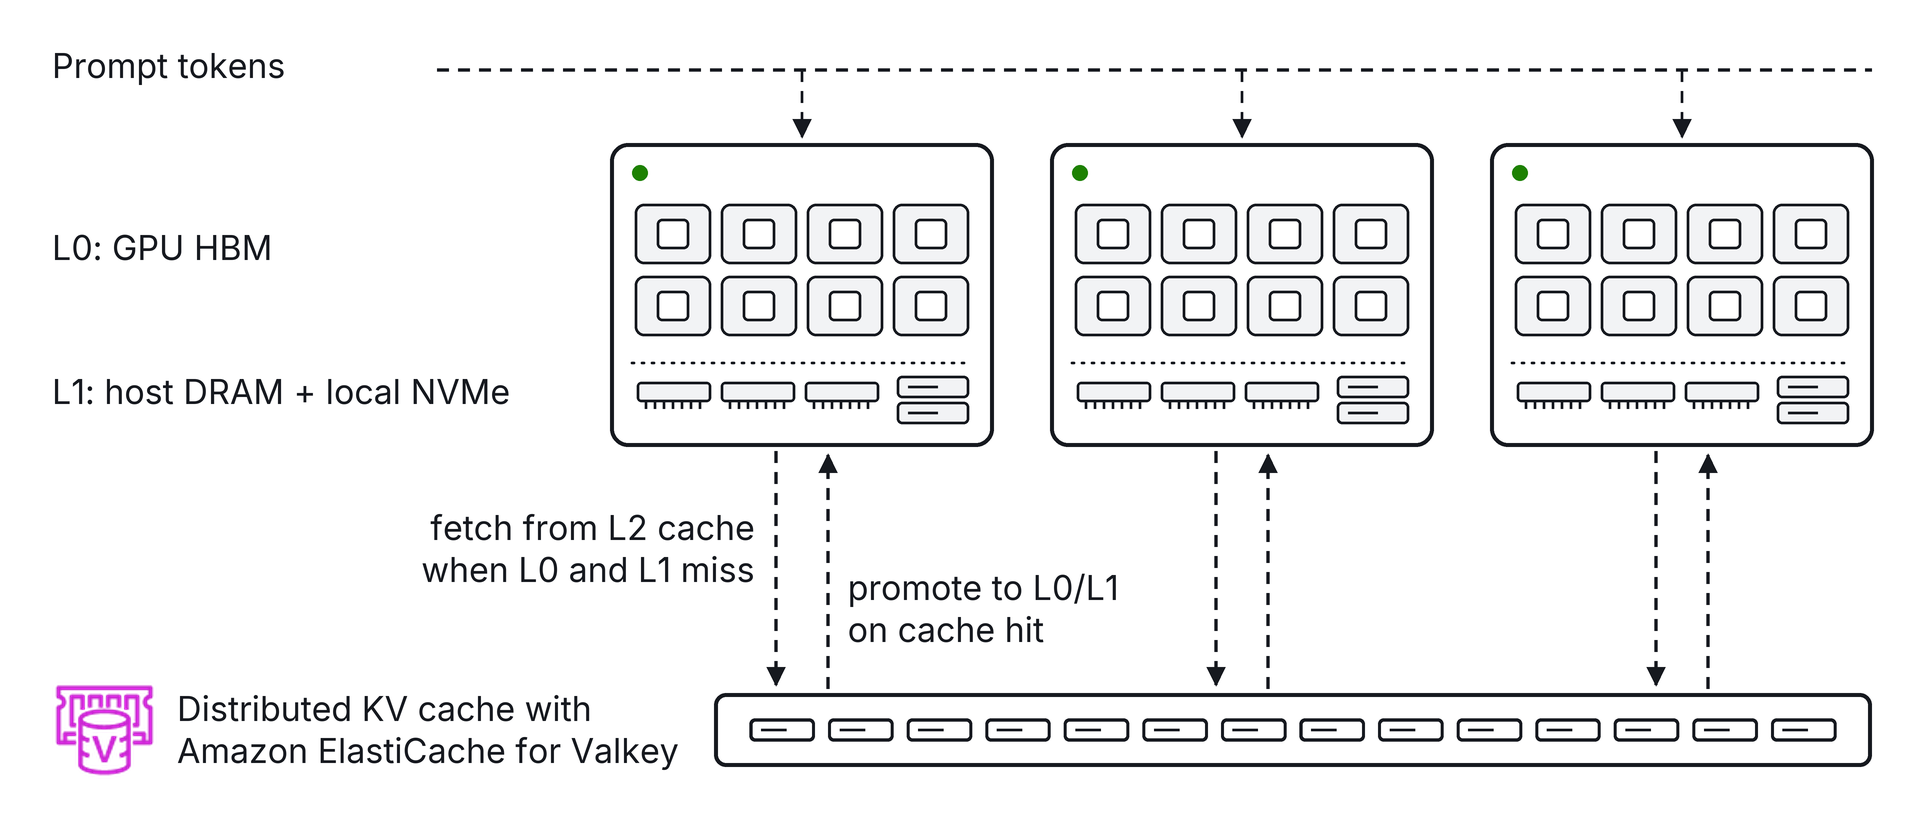
Announcing distributed KV caching for self-hosted LLMs with Amazon ElastiCache
0AWS Database Blog
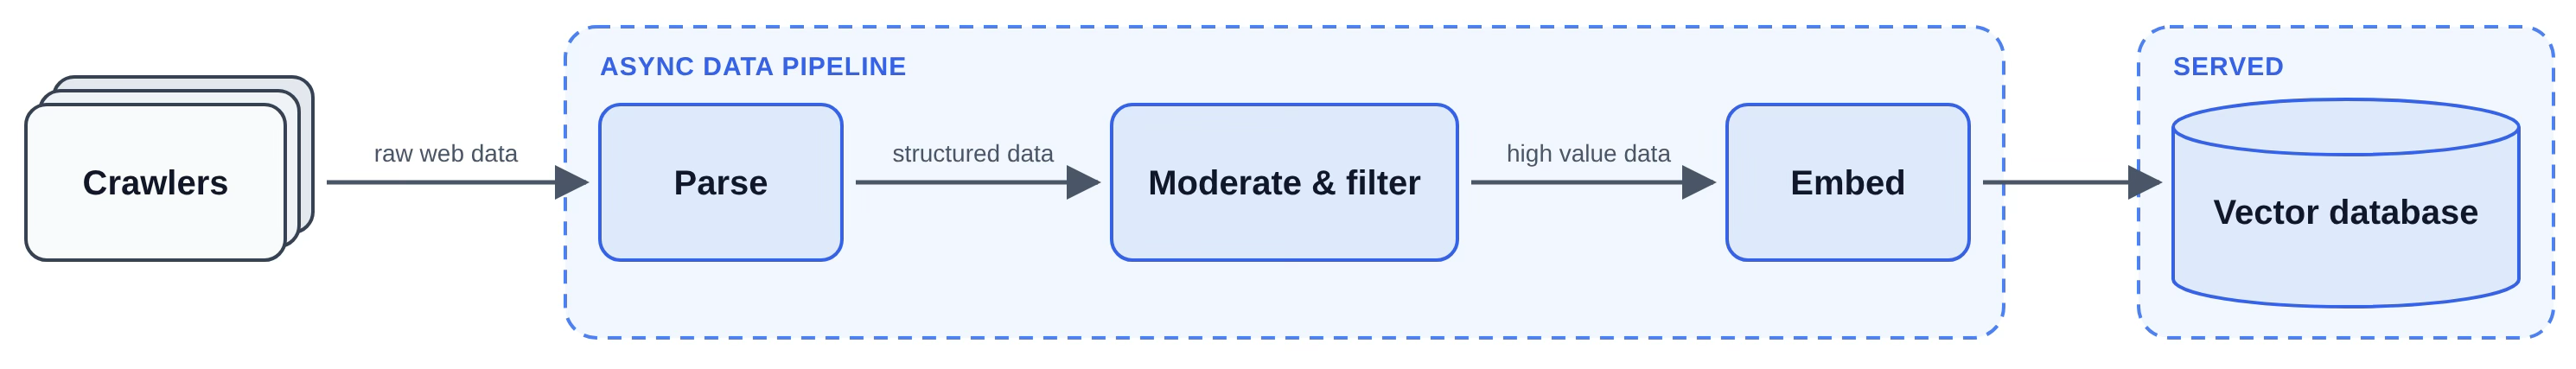
Exa boosts embedding throughput by 50% to index billions of documents on AWS AI chips
0AWS Machine Learning Blog