AI & ML
Parallel Branch Model Predictive Control on GPUs
arXiv cs.RO0 views
arXiv:2506.13624v3 Announce Type: replace-cross Abstract: We present a GPU-based solver for trajectory planning problems using branch model predictive control. Building on iterative LQR methods, we adopt a multiple-shooting formulation for the system dynamics and use an augmented Lagrangian method to handle general stage-wise constraints. This design enables straightforward warm-starting. The constraint-handling capability of our solver is validated on two challenging trajectory planning problems. In addition, we develop two tailored inner LQR solvers that exploit the tree-sparse structure. The solvers offer different levels of parallelism, making them appropriate for different tree sizes. The numerical results demonstrate that, compared to a high-performance CPU-based solver, our approach achieves superior performance on large-scale problems.
Source:https://arxiv.org/abs/2506.13624Previous3D-MoE: Towards Spatial Intelligence with Mixture-of-Experts for 3D Reasoning and Action GenerationNextSparse Video Generation Propels Real-World Beyond-the-View Vision-Language Navigation
Related posts

Why I Built a Privacy-First ATS Resume Checker That Runs in the Browser
0dev.to

Local AI on a PC: what actually works (Whisper, translation, LLMs)
0dev.to

LLM assisted reverse engineering
0Hacker News

Palo Alto Networks to Acquire Applied Compute for $4.5B
0Hacker News
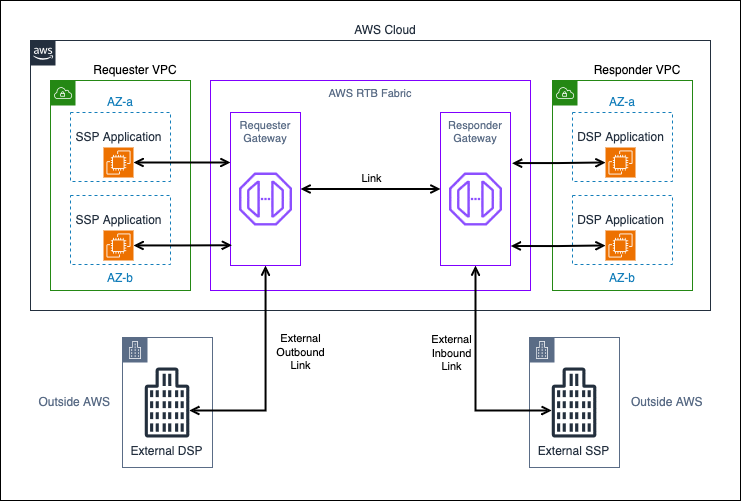
Building highly available real-time bidding workloads with AWS RTB Fabric
0AWS for Industries

Thống kê đối đầu Rayo Vallecano vs Valencia: Xu thế bế tắc và quy luật chia điểm áp đảo
0dev.to Data