AI & ML
What Limits mmWave Human-State Sensing for Robot Perception?
arXiv cs.RO0 views
arXiv:2611.08863v1 Announce Type: new Abstract: Assistive robots and search-and-rescue platforms require reliable human state sensing in smoke, darkness, and privacy-sensitive environments, where cameras and LiDAR may be unreliable Millimeter-wave radar offers an alternative that works without ambient light, penetrates smoke, and does not capture visual appearance. However, the compact arrays that fit robot size, power, and cost budgets have limited apertures, producing joint-localization errors on the order of decimeters at a few meters, large enough to compromise the safety margins and tracking accuracy a robot depends on. Existing pipelines reduce pose error through frame fusion, multiple viewpoints, return selection, or stronger estimators, but examine one technique at a time, without relating its effect to a shared measurement limit or separating gains from added information from gains from estimator completion. We address this gap with a framework that models the human and environment as one time-varying scattering field and states a Cramer-Rao type error floor for joint localization as a function of bandwidth, aperture, signal-to-noise ratio, fused frame count, phase coherence, and visibility of retained returns. We then use existing frame fusion, multi viewpoint, return selection, and pose estimation methods as matched probes of this floor rather than as competing pipelines. Under the evaluated conditions, experiments on three datasets and a live deployment show these strategies move joint localization error in the predicted directions, for example lowering mean per-joint position error from about 97 to 65 mm with a second viewpoint, while a stronger estimator mainly lowers overall error by completing joints the measurement cannot resolve. These results give the robotics community a principled basis for deciding whether to prioritize observation design or estimator capacity when deploying reliable mmWave human sensing.
Source:https://arxiv.org/abs/2611.08863PreviousSTRIDE: Learning Humanoid Locomotion in Minutes with Acceleration-Based RewardsNextLodos-v2: An Efficient Primal Formulation of the Exact Frictional Contact Problem
Related posts

Instagram’s AI age detection is expanding globally
0The Verge
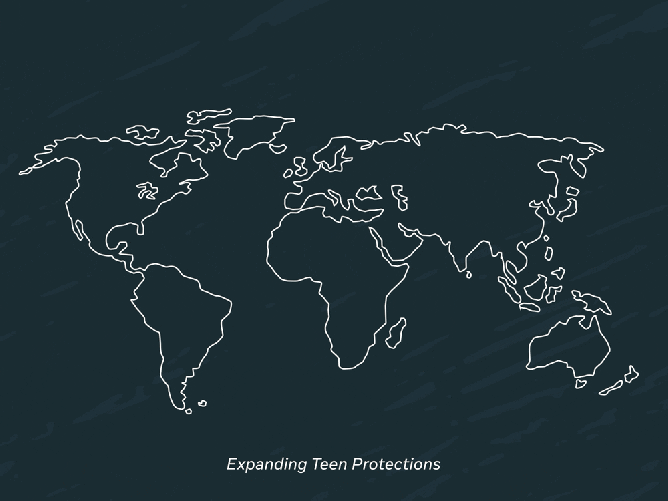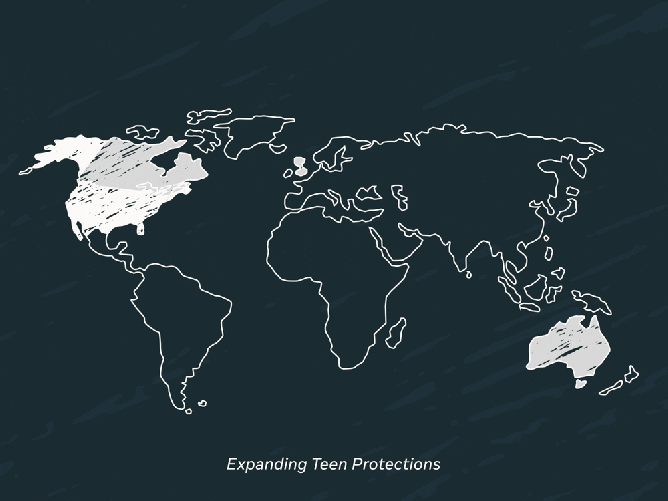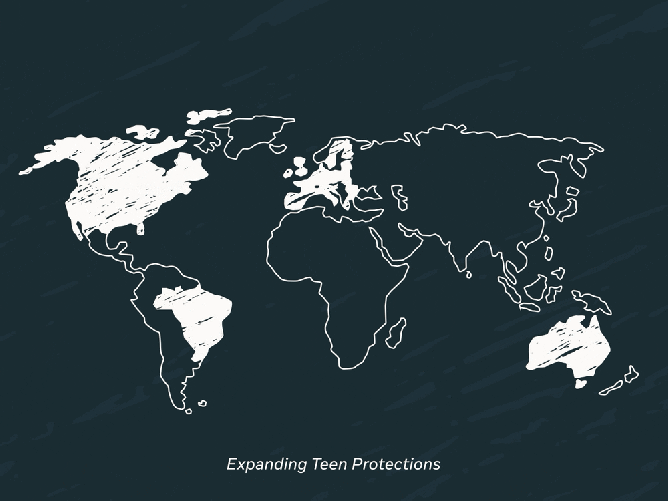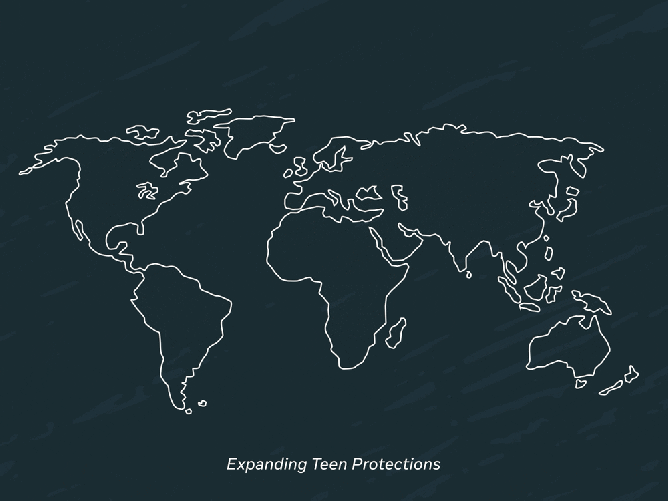
Expanding Teen Account Protections to Teens Around the World
0Meta Newsroom

Tối ưu hóa hiệu suất đầu ra: Tiền vệ Njie vực dậy hàng công Fiorentina với 5 lần in dấu giày
0dev.to Data

Hiệu suất săn bàn ấn tượng của Gouiri thúc đẩy chuỗi toàn thắng của Marseille
0dev.to Data

Hiệu suất săn bàn vượt trội của Kylian Mbappé trong màu áo Real Madrid
0dev.to Data

Hiệu suất toàn diện đưa Harry Kane vượt mặt Kylian Mbappe và Lamine Yamal trên bình diện thế giới
0dev.to Data